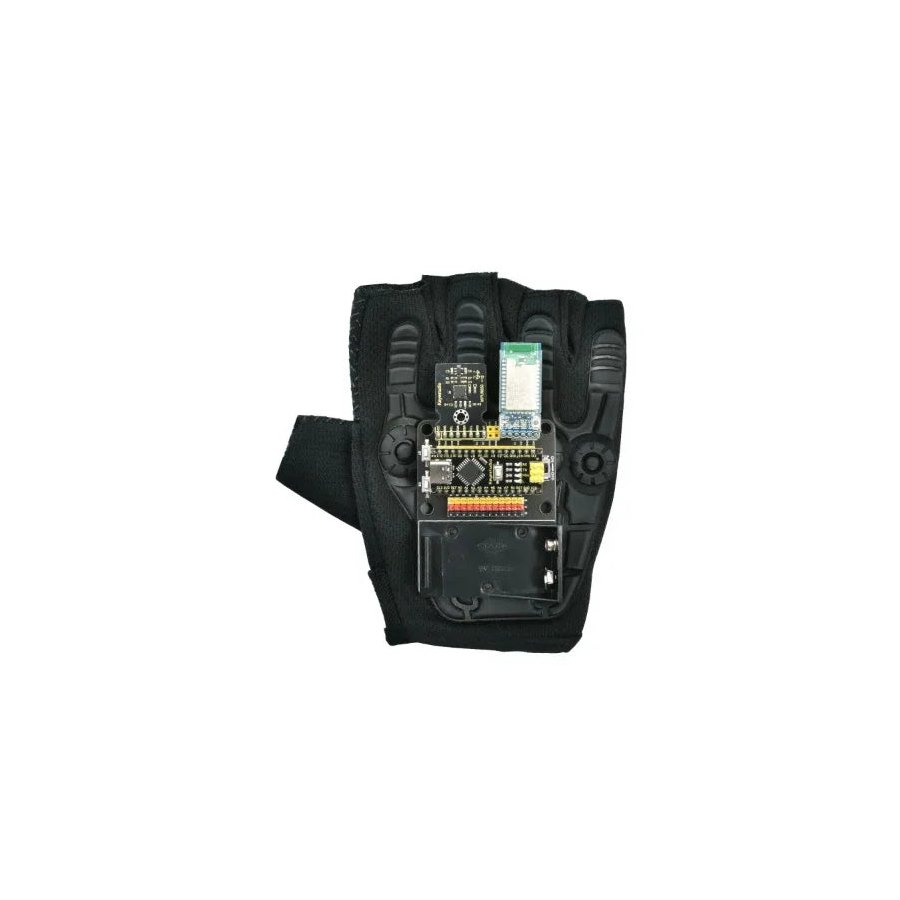
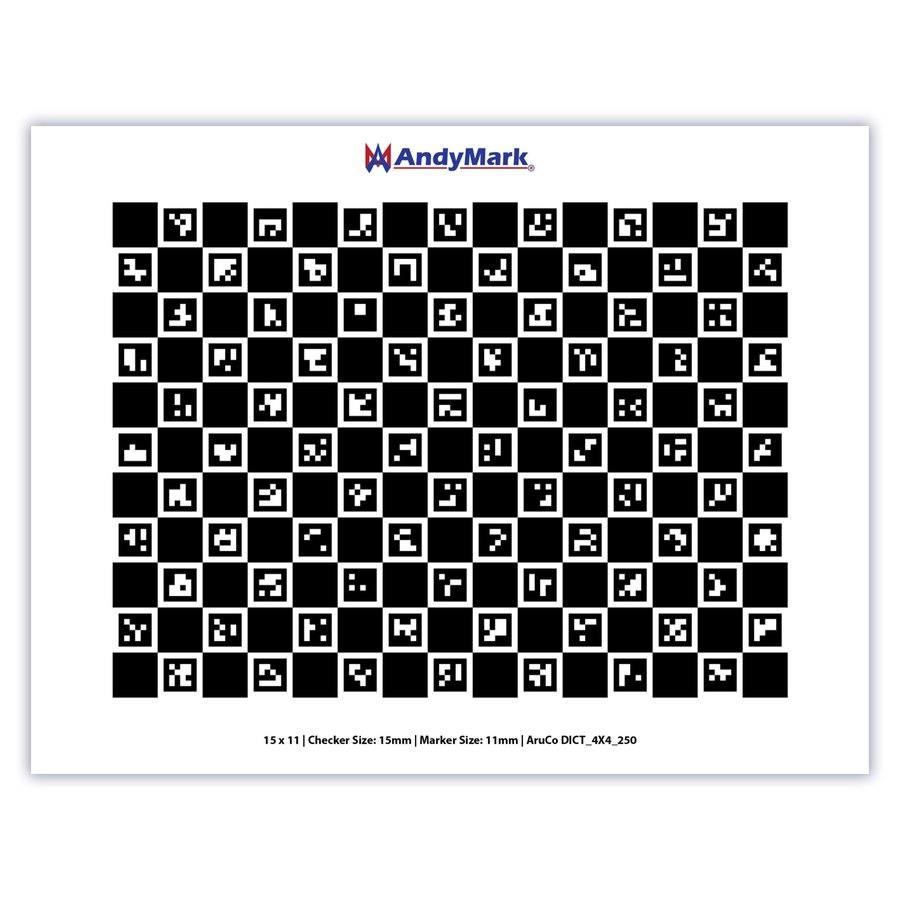
Hardware for building robot-learning datasets: handheld capture grippers, teleoperation rigs, motion-capture gloves, wrist cameras, sync boxes and calibration targets. Research groups buy these in small numbers and cannot afford a broken rig mid-collection.