Handheld capture grippers, teleoperation rigs, dexterous hands and the sensor stacks behind robot-learning datasets.
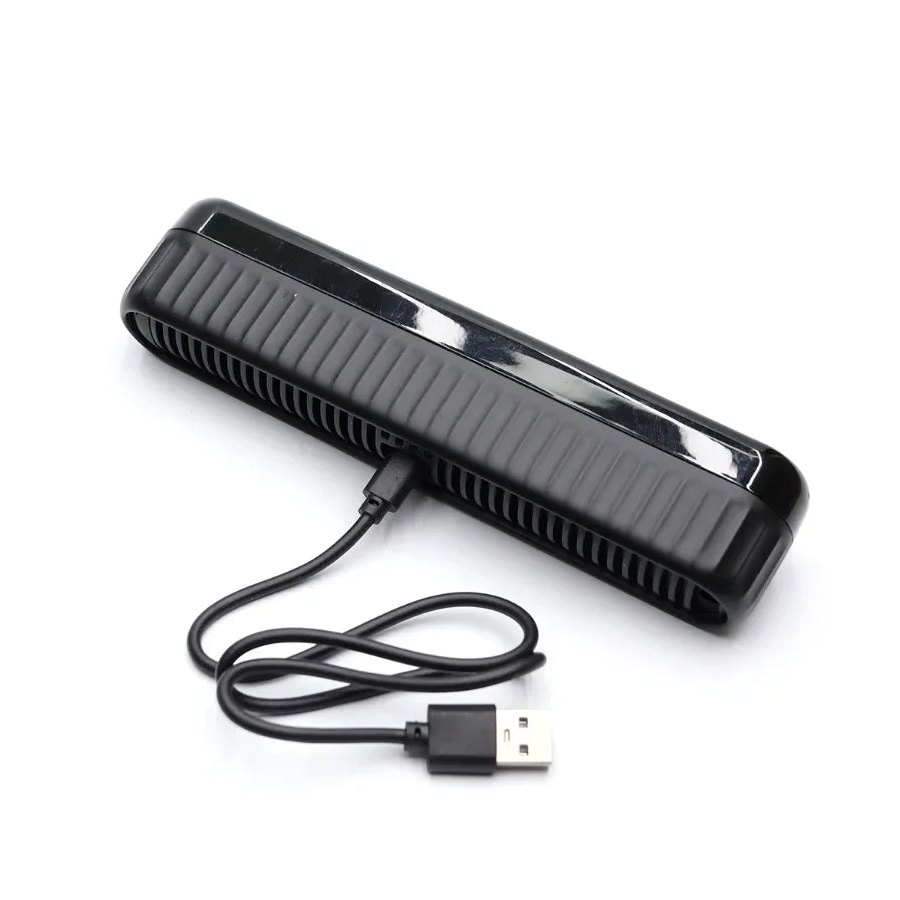 Core component
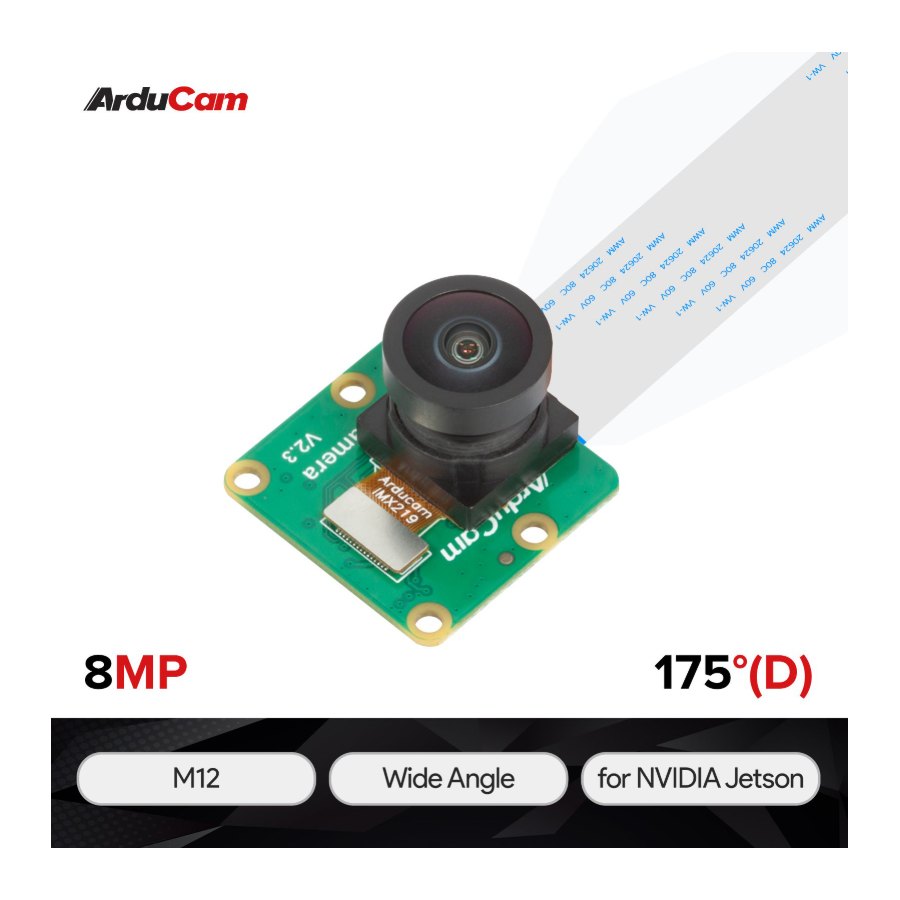 Core component
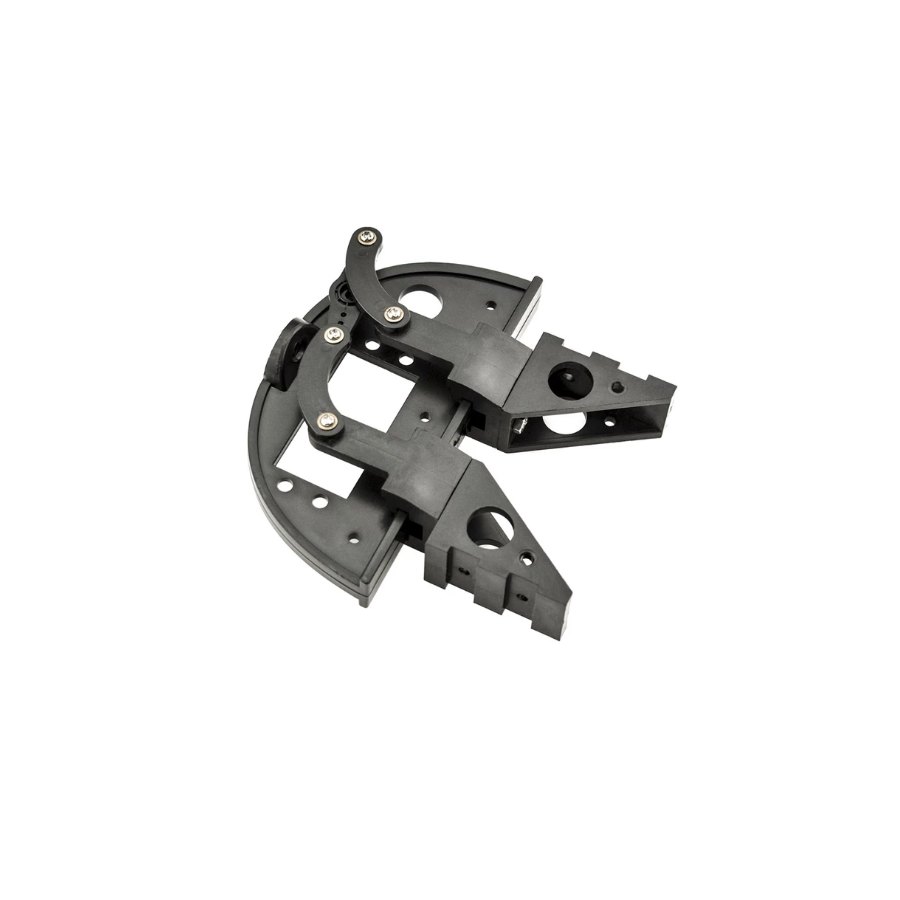 Core component
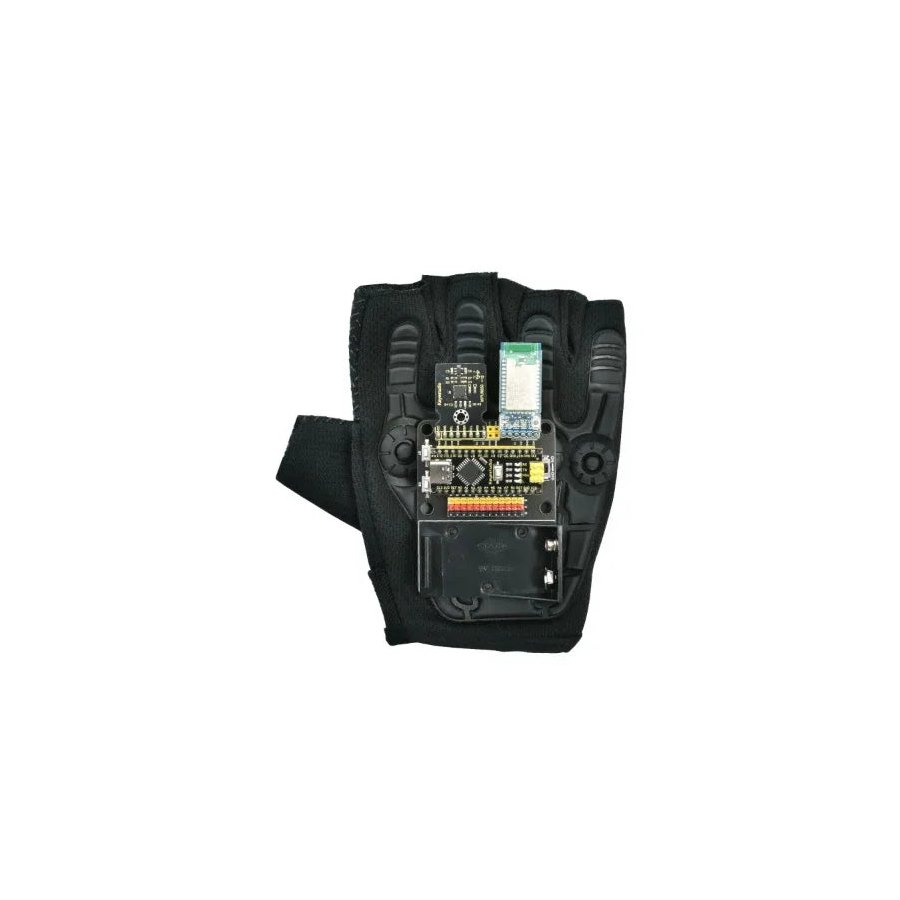 Core component
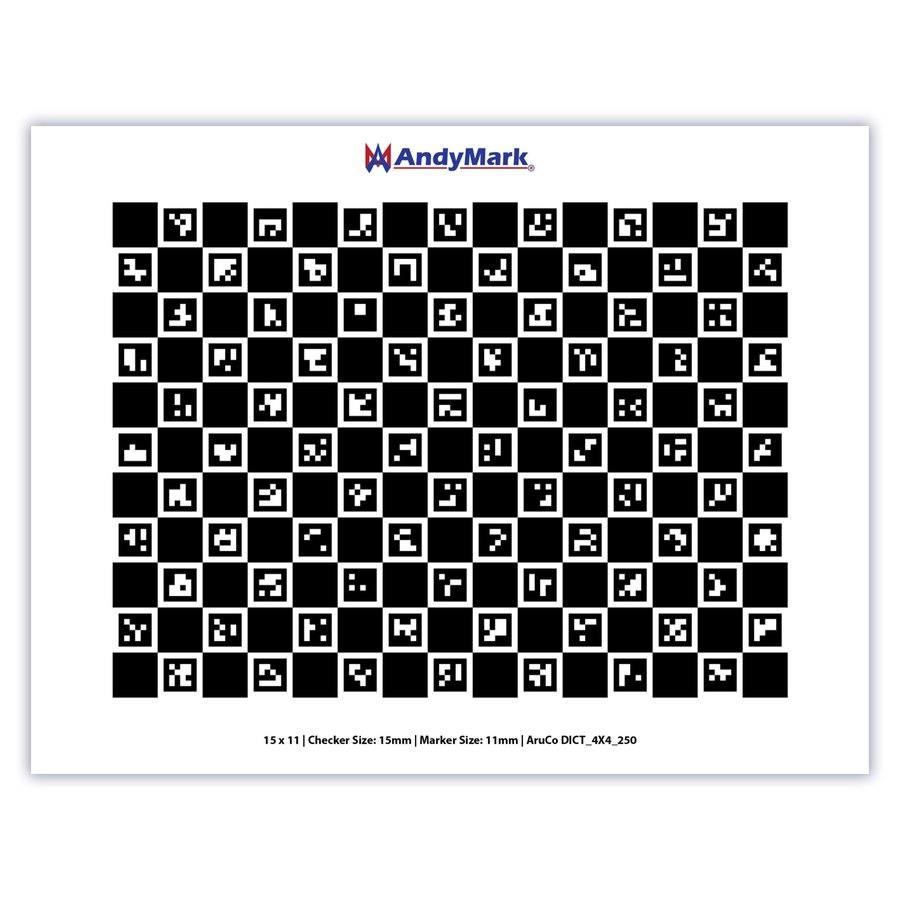 Consumable
 Wear part
 Wear part
Goes first: Fingertip pads, fisheye lenses, cables and connectors, calibration targets, storage media.
